Linux Automation Platform for Industrial Motion Control & DrivePLCs
Baumüller introduces its Linux-based runtime environment and updated ProMaster engineering system to unify centralized and drive-integrated machine automation.
www.baumueller.com
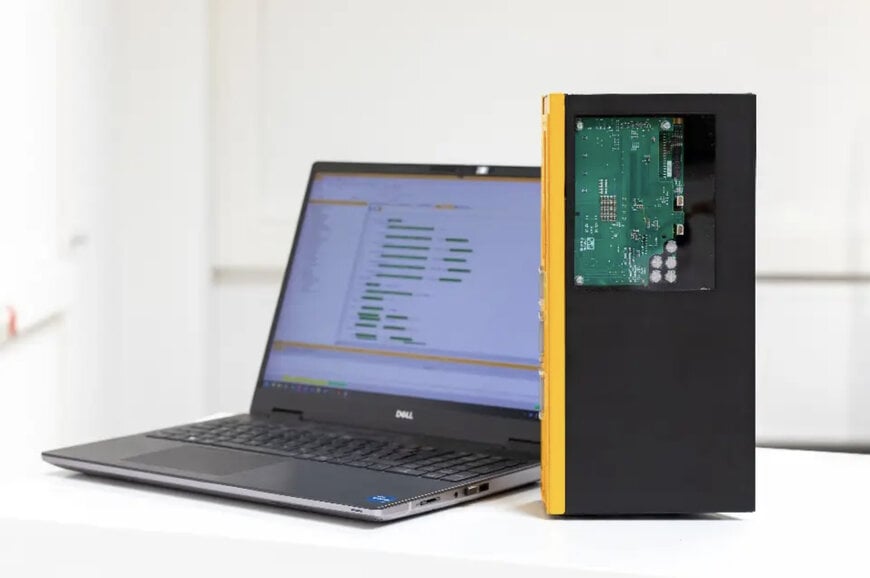
Modern machinery manufacturing requires high-speed deterministic coordination across distributed axes while demanding open interfaces for data-intensive processing and operational analytics. To resolve the architectural trade-offs between proprietary control hardware and high-level software flexibility, Baumüller is launching an end-to-end automation platform powered by a processor-independent Linux runtime environment and an updated release of its ProMaster engineering framework, establishing a unified software foundation for both centralized controllers and decentralized b maXX drivePLC units.
Distributed Control Architecture and Processor-Independent Execution
Industrial machine builders frequently encounter integration bottlenecks when attempting to bridge low-level servo regulation with edge-level supervisory applications. Traditional closed runtime systems restrict third-party software deployment, isolating real-time deterministic axis control from operational data analytics.
Baumüller’s automation architecture decouples control algorithms from proprietary silicon by establishing a processor-independent runtime hosted on an open Linux kernel. This configuration enables machine builders to deploy real-time control routines alongside containerized edge microservices, condition monitoring algorithms, and artificial intelligence models on identical hardware. By interfacing directly with b maXX 6000 series servo drives and the b maXX drivePLC, the runtime processes high-frequency drive data locally, facilitating predictive maintenance and anomaly detection without saturating the primary industrial Ethernet bus.
Deterministic Motion Control via Standardized Software Frameworks
To maintain execution compliance across diverse machinery layouts, the runtime platform is structured in full conformity with the IEC 61131-3 programming standard. Motion sequences utilize comprehensive PLCopen-compliant motion control function blocks, allowing multi-axis path interpolation, electronic gearing, and camming routines to be transferred across decentralized drives or centralized machine controllers without code rework.
Engineering workflows are managed within the updated ProMaster engineering suite, which combines project planning, parameterization, high-level programming, commissioning, and system diagnostics in a single environment. Key technical capabilities include:
- Object-Oriented Architecture: Engineers can develop modular machine code using object-oriented extensions alongside high-level programming languages such as C++.
- Software Reuse: Pre-validated machine modules, technology libraries, and functional templates from previous engineering iterations remain fully functional under the updated architecture.
- Automated Testing Routines: Continuous integration protocols allow automated validation of software builds, isolating logic errors and timing anomalies prior to physical machine commissioning.
Baumüller will present the new automation platform, the updated ProMaster engineering software, and compatible drive hardware at the SPS 2026 trade exhibition in Nuremberg, Germany, scheduled for 24 to 26 November 2026 in Hall 1, Stand 560.
Additional Context:
This section details technical specifications and competitive benchmarking not included in the original product announcement.
In industrial motion control, the convergence of real-time automation operating systems with standard Linux distributions is an established industry trend, benchmarked against platforms such as Beckhoff TwinCAT, Siemens SIMATIC runtime environments, and CODESYS-based Linux runtimes. The b maXX drivePLC achieves deterministic task cycles down to 250 microseconds directly within the servo inverter, eliminating the cycle jitter associated with external fieldbus transport for single- and double-axis configurations.
Communication topologies for the platform incorporate real-time industrial Ethernet protocols, including EtherCAT and PROFINET IRT, alongside standardized machine-to-cloud connectivity using OPC UA and MQTT protocols. Control hardware in the b maXX 6000 series satisfies the Ecodesign Directive (EU) 2019/1781 under the IE2 efficiency classification for drive controllers.
To comply with contemporary machine safety directives, the platform integrates drive-based functional safety protocols (Fail Safe over EtherCAT / PROFIsafe) meeting SIL 3 according to IEC 61508 and PL e according to ISO 13849-1. Furthermore, implementing an open Linux environment requires compliance with the industrial automation cybersecurity standard IEC 62443-4-1 and IEC 62443-4-2, ensuring secure boot mechanisms, role-based user authentication, and encrypted parameter transfer across the automation lifecycle.
Edited by Natania Lyngdoh, Induportals editor, with AI assistance.
www.baumueller.com