www.ptreview.co.uk
06
'26
Written on Modified on
EV Charging Infrastructure Controller Integration Architecture
Beckhoff integrates OCPP communication via TwinCAT 3 and the EL6761 EtherCAT Terminal to standardize electric vehicle charging management and vehicle-to-grid communications.
www.beckhoff.com
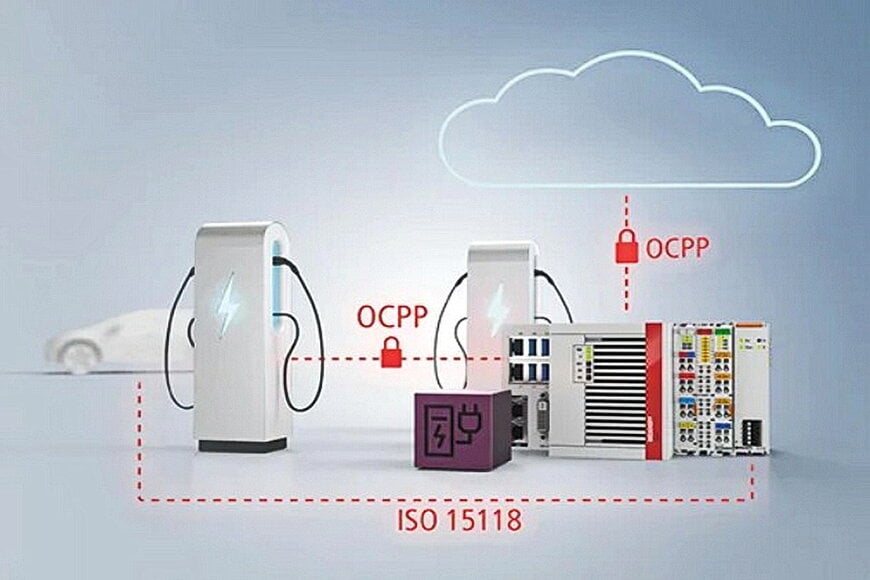
Interoperability challenges between charging stations, grid operators, and backend management platforms have historically complicated commercial electric vehicle charging rollouts. Beckhoff addresses this operational fragmentation by introducing native Open Charge Point Protocol capabilities into its automation platform alongside a dedicated I/O interface, integrating station control, grid interaction, and backend communication within an industrial automotive data ecosystem.
The engineering challenge in charging infrastructure centers on reconciling real-time low-level signaling with cloud-based digital supply chain logistics and energy accounting. Station hardware must govern physical power electronics, verify vehicle safety parameters, negotiate charge rates, and report diagnostic and billing metrics to central operators without vendor lock-in. Unifying these functions into an industrial PC-based automation stack eliminates redundant intermediate gateways, consolidating operational control and networking into a deterministic hardware environment.
Operating Mechanism and Protocol Architecture
The core of the software implementation is TwinCAT 3 IoT OCPP (TF6771), which provides an OCPP interface realized as a C++ driver wrapped by an integrated PLC library. Communication is established using WebSockets, matching the secure transport requirements mandated by modern networked management stations. The software supports both OCPP 1.6 and OCPP 2.0.1 profiles, ensuring compatibility with legacy operations while supporting advanced encryption, smart charging topologies, and transaction diagnostics.
Physical connectivity to the vehicle is handled by the EL6761 1-channel EtherCAT Terminal, which mounts directly on the DIN-rail automation rack. The module operates as a dedicated communication bridge handling low-level signaling standards:
- Pulse-width modulation signaling conforming to IEC 61851 for basic pilot control, state detection, and safety interlocks.
- Powerline communication according to ISO 15118 over the control pilot line, supporting high-level bidirectional data exchanges for dynamic power negotiation, vehicle identification, and automated authorization.
Industrial Topologies and Deployment Models
Within automation engineering designs, this combined software and terminal architecture supports two distinct operational frameworks:
In the endpoint configuration, the TwinCAT controller functions directly as the real-time charging point manager. Paired with the EL6761 EtherCAT Terminal, it monitors electrical hardware, executes safety loops, interfaces with the vehicle, and connects outward as an OCPP client to a central management system.
In the supervisory configuration, TwinCAT acts as a regional controller or intermediate node within the charging network. In this mode, it receives status and telemetry from downstream charging stations over OCPP to coordinate local load shedding, peak-shaving, and energy distribution alongside onsite battery storage or photovoltaic systems. Simultaneously, TwinCAT interfaces upstream with higher-level billing, authentication, and enterprise energy management software.
Additional Context
This section details technical specifications and competitive benchmarking not included in the original product announcement.
Traditional electric vehicle supply equipment designs commonly segregate control logic: microcontrollers run real-time pilot signaling, proprietary charge controllers govern power stages, and external single-board computers manage OCPP-to-cloud networking over Linux environments. This fragmented model introduces latency and multiple points of failure.
In contrast, Beckhoff's modular approach executes both vehicle-to-charger protocols (IEC 61851/ISO 15118) and charger-to-cloud interfaces (OCPP 1.6/2.0.1) on a single IPC runtime. The ISO 15118 standard implemented on the EL6761 supports the cryptographic handshake necessary for automated "Plug & Charge" implementations, aligning with global charging interface benchmarks such as the Combined Charging System standard.
By executing the application inside an EtherCAT automation environment, power distribution logic can sample grid meter inputs and dynamically throttle vehicle draw within cycle times under 1 millisecond. This provides grid-compliant balancing that standalone, cloud-tethered EV chargers operating over non-deterministic operating systems cannot replicate.
Edited by Evgeny Churilov, Induportals Media - Adapted by AI.
www.beckhoff.com