www.ptreview.co.uk
06
'26
Written on Modified on
Edge AI Computer Vision Integration for Autonomous Systems
SINTRONES Integrates Stereolabs GMSL-2 Cameras Into IBOX-650P and IBOX-601 Edge AI Computers for Multi-Camera Vision Applications.
www.sintrones.com
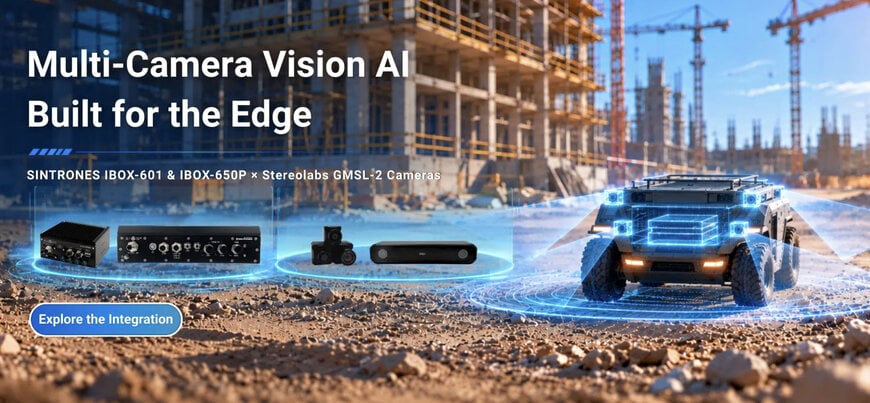
Autonomous systems, mobile robotics, and industrial automation platforms require high-bandwidth, low-latency visual perception pipelines to interpret dynamic environments in real time. Processing uncompressed high-resolution data streams from multiple cameras simultaneously imposes heavy demands on embedded computing architectures, particularly regarding bus throughput, synchronization, and thermal dissipation at the edge.
To address these engineering challenges, SINTRONES Technology Corp. announced on October 2, 2026, in Taipei, Taiwan, that its NVIDIA Jetson AGX Orin-powered IBOX-650P and Jetson Orin NX-powered IBOX-601 series now support multi-camera integration with Stereolabs GMSL-2 cameras. This hardware integration provides system integrators with scalable options for multi-camera vision AI deployments across industrial automation, robotics, autonomous vehicles, and smart surveillance.
Gigabit Multimedia Serial Link Architecture for Edge Computing
The IBOX-650P and IBOX-601 platforms integrate Analog Devices GMSL-2 deserializer technology to manage high-bandwidth, uncompressed video streams. GMSL-2 architecture enables cable runs of up to 15 meters over coaxial cabling while maintaining low-latency, synchronized data transmission, which is critical for multi-perspective machine vision systems.
Depending on the specific hardware layout, deserializer configuration, and Board Support Package release, supported configurations accommodate up to four GMSL-2 camera connections. The verified compatible camera models include the Stereolabs ZED X Stereo and the ZED X One 4K, S, and GS variants. This compatibility allows developers to combine 3D stereo depth perception with high-resolution 2D monocular imaging on a single edge computing platform.
Synchronized 3D Depth and 2D Monocular Processing
The integration allows dual-modality vision processing by pairing the ZED X Stereo camera with ZED X One monocular units. The ZED X Stereo features dual lenses and a global shutter sensor, capturing distortion-free 3D depth data in motion for precise object tracking and spatial mapping. Simultaneously, the ZED X One S and GS models utilize global shutter sensors to eliminate motion blur, while the ZED X One 4K provides high-resolution imaging in low-light conditions using a 4K rolling shutter sensor.
This combination enables continuous, low-latency data capture for edge AI inference models running on the underlying NVIDIA Jetson architecture. System integrators can leverage the heterogeneous compute capabilities of the Jetson AGX Orin and Orin NX modules to process parallel neural networks for object detection, depth estimation, and semantic segmentation without incurring performance bottlenecks.
Industrial Deployment Scenarios
The IBOX-650P and IBOX-601 series are engineered for deployment in harsh industrial and mobile environments requiring fanless thermal design and robust mechanical resilience. Typical application areas include autonomous mobile robots navigating complex warehouse floors, intelligent transport systems requiring 360-degree perimeter surveillance, and automated optical inspection systems in advanced manufacturing lines.
Supported camera configurations and simultaneous operating limits depend on the deployed BSP version, system configuration, and physical interface layout. System integrators are advised to verify compatibility requirements prior to physical deployment.
Additional Context:
This section details technical specifications and competitive benchmarking not included in the original product announcement.
Edge AI platforms operating in mobile and industrial environments face significant challenges regarding thermal management, power envelope constraints, and physical vibration. Traditional USB or Ethernet-based multi-camera setups often suffer from bandwidth saturation, high CPU overhead for packet handling, and unreliable cable connections under mechanical stress. GMSL-2 technology resolves these limitations by providing dedicated high-speed serial point-to-point links with embedded power and control channels over a single coaxial cable.
Compared to traditional Gigabit Ethernet vision systems, GMSL-2 architectures offer lower protocol overhead and deterministic frame synchronization across multiple sensors. This precise hardware-level synchronization is essential for stereo-slam and multi-camera sensor fusion algorithms, where microsecond-level timing discrepancies between frames can introduce significant spatial mapping errors in fast-moving autonomous systems.
Edited by Sucithra Mani, Induportals editor – adapted by AI.
www.sintrones.com