www.ptreview.co.uk
30
'26
Written on Modified on
Bosch Rexroth Sponsors ROSCon IT 2026 for Smart Intralogistics
The company will present ROS 2 solutions integrating autonomous mobility and advanced robotic manipulation.
www.boschrexroth.com
Bosch Rexroth will participate as a Gold Sponsor at ROSCon IT 2026, the Italian conference dedicated to Robot Operating System (ROS) developers, which will be held on November 3 in Bologna. The event, coordinated by the Open Source Robotics Alliance (OSRA), represents a crucial meeting point for the open-source automation ecosystem. In this context, the Bosch Group company will reaffirm its commitment to developing open industrial solutions that blend software, flexible control systems, and advanced robotics.
ROS 2 and the Evolution of Automated Kitting
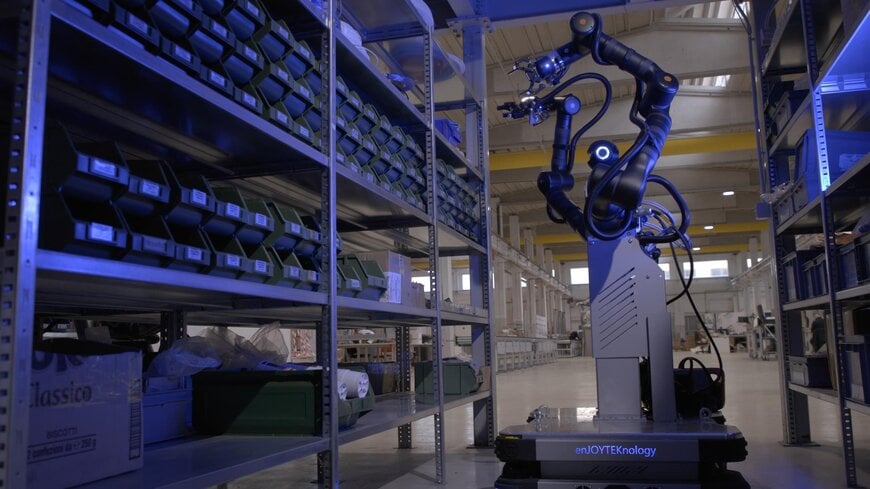
The core of Bosch Rexroth's participation will be the integration of the ROS 2 framework into distributed applications and complex robotic systems. During the event, Flavio Ronzoni, Product Manager at the company, will illustrate a concrete application case dedicated to intralogistics: an automated kitting project developed in close collaboration with Reply and Joytek. This platform demonstrates how autonomous mobility can be seamlessly combined with robotic manipulation, transforming the open-source architecture into a scalable and interoperable solution ready for industrial production environments.
Additional Context: ROS 2 Architecture and DDS Middleware in Industry
This section describes robotic software architectural dynamics not included in the original press release.
In the shift from academic research to mission-critical industrial automation, the transition from the ROS 1 framework to ROS 2 represented a technological watershed for robotics. While ROS 1 relied on a centralized architecture (via a single "ROS Master" node) vulnerable to bottlenecks and single points of failure, ROS 2 is natively built upon the industrial DDS (Data Distribution Service) standard. This peer-to-peer communication middleware guarantees a deterministic quality of service (QoS), essential for real-time control. In complex scenarios like mobile kitting—where a robotic arm (cobot) mounted on an Autonomous Mobile Robot (AMR) must navigate, identify components via machine vision, and pick them while in motion—network latency and data loss are intolerable. The integration of ROS 2 and DDS allows LIDAR sensors, cameras, and actuators to exchange encrypted data in a decentralized and synchronous manner, making heterogeneous robotic fleets suitable for the strict safety and reliability standards of smart factories (Industry 4.0).
Edited by industrial journalist Lekshman Ramdas, with AI assistance.
www.boschrexroth.com