www.ptreview.co.uk
11
'26
Written on Modified on
Microchip launches the ATFCD52 for tactile robotic grasping
The high-speed capacitive digitizer detects slippage in real time with sub-femtofarad sensitivity.
www.microchip.com
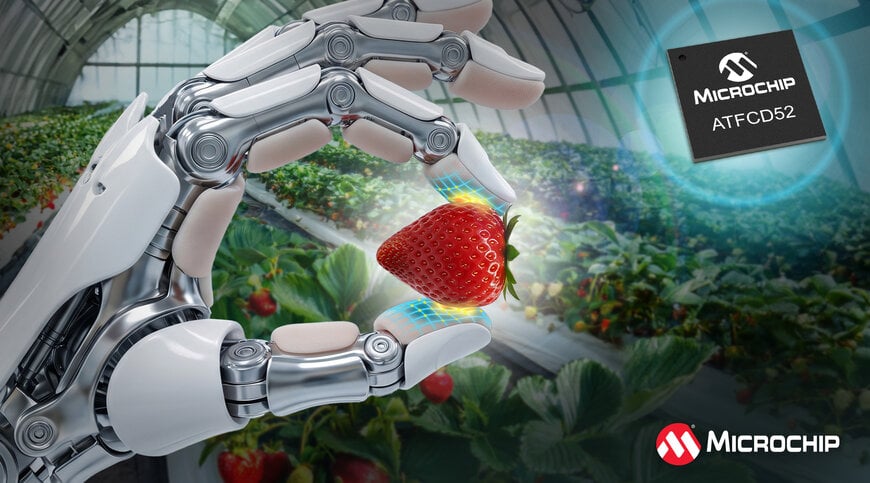
Microchip Technology has introduced the ATFCD52 high-speed capacitive digitizer, designed to equip robotic grippers and humanoid hands with advanced tactile sensitivity. By converting signals from fine-mesh capacitive sensor arrays into digital data, this component enables robotic systems to manipulate soft, fragile, or irregular objects with high dexterity. By calculating normal and tangential forces, control processors can dynamically adjust the gripping force and proactively detect slippage.
Ultra-fast acquisition and noise immunity
Ultra-fast acquisition and noise immunity are key features of the ATFCD52, which supports up to 52 channels, configurable as up to 32 transmit (TX) lines and 20 receive (RX) lines. Thanks to the integration of twenty parallel-operating analog front-end circuits, the component simultaneously acquires all receive lines, achieving a frame rate of 800 Hz. This acquisition speed is crucial for correcting gripping in a fraction of a second, before an object falls or is crushed. Furthermore, the digitizer offers extreme sensitivity, capable of detecting capacitance variations smaller than one femtofarad (1 fF). To ensure the reliability of these minute signals in environments heavily disturbed by servomotors and power electronics, the chip natively integrates frequency hopping and oversampling algorithms.
Development Ecosystem and Hardware Integration
Designed for seamless integration into a comprehensive architecture, the ATFCD52 pairs with Microchip microcontrollers (MCUs), microprocessors (MPUs), and FPGAs, depending on the application's bandwidth and computing requirements. To accelerate prototyping and evaluation of tactile sensor stacks, the company offers the EV-ATFCD52 development board, coupled with the ATFCD52 Configurator software. In addition to industrial robotics, this matrix scanning technology also applies to augmented reality, wearable devices such as electronic skin, and advanced tactile instrumentation equipment.
Additional background: Dielectric elastomers and sub-femtofarad metrology
This section details the physical principles of capacitive sensing and electromagnetic interference, which are not included in the original press release.
In tactile robotics, a capacitive sensor array typically consists of a flexible dielectric elastomer sandwiched between two flexible electrode grids (the TX and RX lines). When a robotic arm grasps an object, the mechanical pressure compresses this elastomer, reducing the distance (d) between the electrodes. According to the laws of electrostatics, this local compression proportionally increases the electrical capacitance. Imminent slippage generates tangential micro-vibrations and shear waves that dynamically modify the overlap zone (A) or induce asymmetric pressure variations on the sensor surface.Measuring a variation on the order of a femtofarad (10-15 farads) falls under the domain of ultra-high-precision metrology. By comparison, the mere parasitic capacitance of a copper trace on a standard printed circuit board is measured in picofarads (1,000 times greater). In a robotic system, servomotors are driven by pulse-width modulation (PWM) inverters, generating extremely steep voltage edges (high dV/dt). These power switching operations induce massive electromagnetic noise that couples directly to the touch sensor signal lines. Advanced techniques such as frequency hopping are therefore essential to dynamically shift the ATFCD52 measurement frequency away from the motor noise harmonics, thus preserving the integrity of the sub-femtofarad touch signals.
Edited by industry journalist Lekshman Ramdas, with AI assistance.
www.microchip.com
