Robot End-of-Arm Tooling With AI Gripping
Festo combines pneumatic and electric grippers, vacuum technology, Vision Guided Motion and GripperAI software to simplify robot integration across automation applications.
www.festo.com
In robotic automation, the end-of-arm tooling (EOAT) determines whether a robot can handle a part reliably. It is the interface between robot and workpiece, and selecting, designing and commissioning grippers, vacuum systems and vision often takes more engineering time than the robot itself. Festo is extending its gripping and vacuum portfolio with software and artificial intelligence and will present its approach at SPS 2026, held from November 24 to 26, 2026, in Nuremberg, Germany.
The solutions are used in automotive production, electronics manufacturing, packaging, food processing, laboratory automation and machine tools.
From Components to Integrated End-of-Arm Solutions
Festo offers pneumatic and electric grippers and vacuum technology combined with robot integration, software and AI. The company supports users from selection and design through integration and commissioning. Standardised interfaces, engineering tools and software modules are intended to simplify connection to robots from different manufacturers and to shorten engineering and commissioning time.
Vision Guided Motion
Vision Guided Motion (VGM) combines image processing with precise path control. The system locates parts in varying positions and orientations and then guides the robot for gripping and transport or for customer-specific processes such as gluing or screwing. Detecting part position by camera reduces the need for mechanical fixtures and manual teaching, which lowers adjustment effort and increases process reliability.
GripperAI for Unknown Objects
GripperAI is AI-based software that enables robots to recognise unknown or varying objects and to determine suitable gripping points and strategies automatically. This reduces the programming required when new products or part variants are introduced.
Application Example in Food Handling
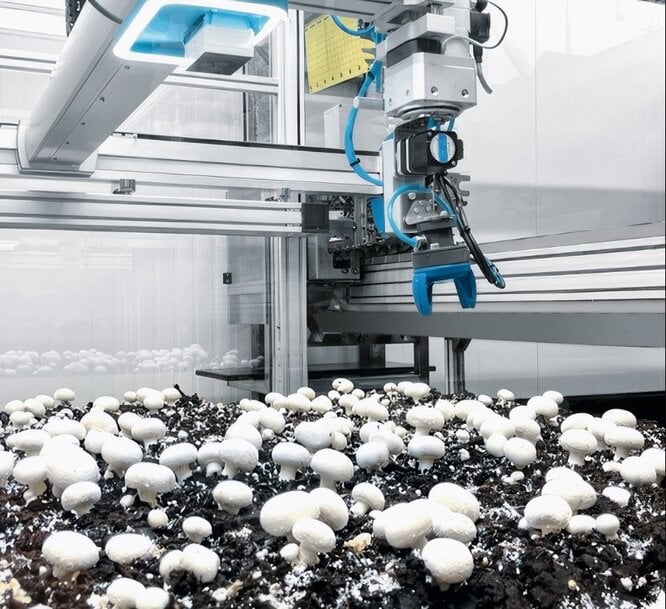
The Mushroom Harvesting Unit shows how these elements work together. It combines AI-supported image processing, a high-precision gantry, a rotating wrist axis and the HPSX adaptive gripper to harvest pressure-sensitive edible mushrooms without damage. The system assesses each mushroom and determines the optimum harvest time.
Further Applications
In electronics, Festo solutions are used for assembling and testing electronic modules, including irregularly shaped components, in microelectronics, photovoltaics and e-mobility. In press shops and body-in-white production, vacuum suction spiders move sheet metal parts with stable processes and short cycle times. In machine tools, tool changers enable fast, automated tool changes.
Additional Context:
This section details technical specifications and competitive benchmarking not included in the original product announcement.
Mechanical interfaces between robots and tools are standardised in ISO 9409-1, which defines robot flange dimensions and supports the use of grippers on robots from different manufacturers. AI-based grasp planning, which computes gripping points from camera or 3D sensor data instead of taught positions, is increasingly used in bin picking, logistics and mixed-product handling. Festo has not published performance data for GripperAI, so no quantitative comparison with other grasp-planning software is made here.
Edited by Evgeny Churilov, Induportals Media - Adapted by AI.
